RoboParty Roboto Origin
RoboParty (Shanghai RoboParty Technology) · Starting from $12,450 · Get a current price
Overview
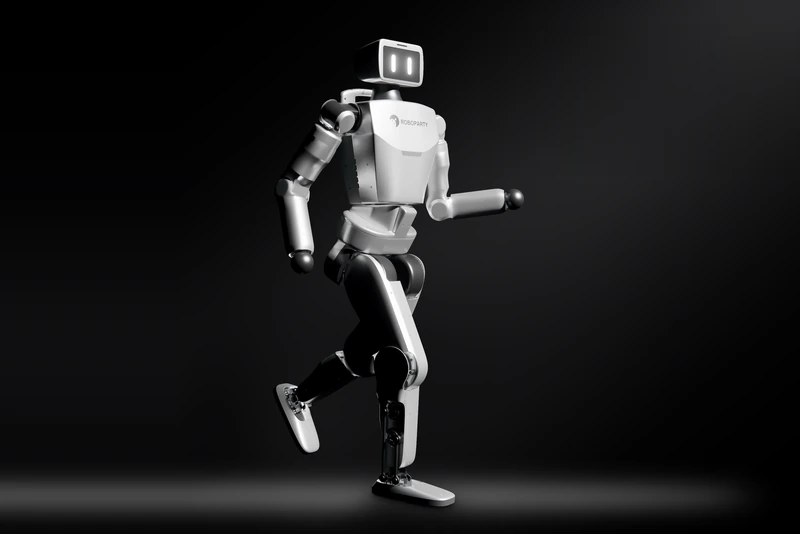
Fully open-source, build-it-yourself bipedal humanoid from Shanghai RoboParty: 1.25 m tall, 34 kg, 23 degrees of freedom (6 per leg, 5 per arm, 1 waist), CNC-machined structure with parallel ankles and human-like offset joints, 48 V / 15 Ah battery, about 3 m/s top speed and more than 2 h of runtime. Runs ROS 2 with an RDK X5 main controller, Wi-Fi 6 and Bluetooth 5.2; Intel RealSense D435i and a 3D LiDAR are optional. Mechanical, electronic, control and simulation files are published openly (core software GPL v3, hardware descriptions under CERN-OHL-W 2.0 and CC-BY-SA 4.0).
Software & 3D models
- URDF: yes
- MuJoCo: yes
- Isaac Sim (USD): not found
- Gazebo: not found
- CAD (STEP): yes
- SDK: yes
- ROS: not found
- ROS 2: yes
- RoboDK: not found
Checked 2026-10-17. Links are not published; we share them with clients.
Variants & pricing
| Variant | Status | Available | Current price |
|---|---|---|---|
| Official Full Kit (battery not included, backordered) | limited | — | $12,450.0 |
Get a price for the RoboParty Roboto Origin
We work from Hangzhou with Chinese and international robot makers. Tell us what you need and we check the current price, lead time and delivery to your country, and reply by email. Our fee comes from you, never from the seller.
A real person reads this. Reply within 2 business days. How we help buyers of robots from China →
Not sure it can do the job? We simulate the task before you buy →
Full price history
| Price | Date | Variant | Source | Note |
|---|---|---|---|---|
| Contact | 2026-10-17 | Official Full Kit (battery not included, backordered) | RoboParty official site | The official page shows no price; its 'check price' button leads to a Taobao shop listing that could not be read (login/anti-bot page). CNY list price not obtained. |
| $12,450.0 | 2026-10-17 | Official Full Kit (battery not included, backordered) | AIFITLAB (dealer) | Dealer listing 'Roboto Origin V2 Kit', type 'Official Full Kit (NOT INCLUDE Battery)', regular price $12,450.00; page says backordered, ships when back in stock; shipping calculated at checkout. The same page lists partial kits (Kit 1 $11,800, Kit 2 $2,400, Motors Kit $5,000, small parts $300 each). Other published figures were not reproducible: humanoid.guide shows 4,900 USD (inquiry-based, unsourced) and a search snippet quoted $8,950 for the same kit on another AIFITLAB URL; the fetched page shows $12,450. Dealer lists it as backordered; battery not included; VAT/shipping not included, shipped from China (USD, dealer regular price, no VAT basis stated). |
Sensors
- IMU
- Intel RealSense D435i depth camera (optional)
- 3D LiDAR (optional)
Locomotion
bipedal walking, running, jumping
Use cases
research, education, maker, reinforcement-learning development
Software
OS: Ubuntu 22.04 · SDK: ✓ · ROS: ✓ · Open source: ✓ · Languages: Python, C++ · AI: Reinforcement learning (Isaac Lab / rsl_rl training, sim-to-real deployment)
Key facts
- Official spec page (roboparty.com/products/RPO, Chinese, fetched 2026-10-17): height 1.25 m, weight 34 kg, thigh 250 mm, shank 300 mm, arm 440 mm; 23 DoF (arm 5: shoulder 3, elbow 1, wrist 1; leg 6: hip 3, knee 1, ankle 2; waist 1); speed 3 m/s; arm joint peak torque 27 N.m, leg joint peak torque 120 N.m; battery 48 V, 15 Ah; runtime 'over 2 hours' (varies with load); Intel D435i and 3D LiDAR optional; ROS 2, Wi-Fi 6, Bluetooth 5.2, OTA upgrade, low-level control SDK and manual control; CNC machining, parallel ankle, human-like offset joints.
- battery_wh 720 is derived from 48 V x 15 Ah, not a published Wh figure; battery_hours 2 is the lower bound of the official 'over 2 h'. max_speed_kmh 10.8 is converted from 3 m/s.
- Sources per field: official RoboParty page/docs: compute RDK X5 (D-Robotics, named in the flashing docs), dimensions, DoF, speed, torque, battery, ROS 2, Wi-Fi 6. humanoid.guide (third party, fetched 2026-10-17): 10 TOPS, DAMIAO motors, Ubuntu 22.04. GitHub README badges and repos (roboparty/roboto_origin): Isaac Lab / rsl_rl, Python 3.10, C++17, Ubuntu-based Linux. IMU listed in the dealer kit contents. humanoid.guide also lists 5 kg 'strength', which is unlabelled, so payload_kg is null.
- Open source: the official GitHub roboto_origin README states GPL v3 for the core code; rpo_description is CERN-OHL-W-2.0 and rpo_hardware SPDX CC-BY-SA-4.0 (fetched 2026-10-17). The README says the robot can be assembled from Taobao-sourced parts and prototyping services, and that RoboParty was founded 2025-02-21 with the prototype finished within four months.
- Sold as a DIY kit (the dealer lists a V2 kit, currently backordered); the official site offers no assembled units and no price. humanoid.guide lists availability as prototype. Catalog status is 'limited' because the only purchase route found is a backordered dealer kit. The kit excludes the battery: battery_wh / battery_hours describe the official 48 V / 15 Ah pack; the official page's 34 kg weight carries no stated battery basis.
- Distinct from RoboParty's other products ROBOTO 01 (RP1) and RP Hand shown in the site navigation; those are not catalogued here.
- Image: official RoboParty render from the roboto_origin GitHub repository (assets/1280X1280.PNG, 1280 x 1280 source, fetched 2026-10-17), dark studio background, cropped and padded to 800 x 534; the 'ROBO PARTY' wordmark that sat beside the robot in the original was retouched out with a background gradient fill. Only the small mark on the robot's chest remains.
- year_announced is null: no source states an announcement date (RoboParty was founded 2025-02-21 per its GitHub README).
About RoboParty (Shanghai RoboParty Technology)
Shanghai startup (上海萝博派对科技有限公司) building fully open-source humanoid robots and publishing hardware, firmware, training and deployment code on GitHub.
https://roboparty.com · Founded: 2025 · HQ: Shanghai, China
Last updated: 2026-10-17 · Full dataset (CSV/JSON, CC BY 4.0)