Used for: Warehouse & logistics Manufacturing
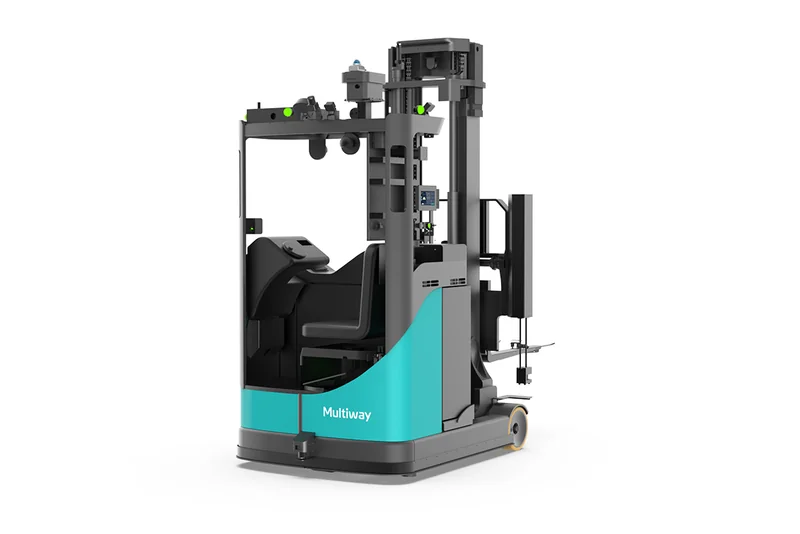
Multiway MW-R16 AMR Reach Truck
Multiway Robotics · Price on request · Get a current price
Overview
MW-R16 is Multiway's autonomous reach truck for pallet stacking and high-level rack access. It carries 1,600 kg, lifts to 9.5 m (750 kg at full height), drives at up to 2 m/s unloaded (1.5 m/s loaded) and runs 8-10 h on a 48 V 450 Ah LFP battery. It navigates with LiDAR (3D SLAM) and recognises pallet pose visually without stopping.
Software & 3D models
- URDF: not found
- MuJoCo: not found
- Isaac Sim (USD): not found
- Gazebo: not found
- CAD (STEP): not found
- SDK: not found
- ROS: not found
- ROS 2: not found
- RoboDK: not found
Checked 2026-10-17. Links are not published; we share them with clients.
Variants & pricing
| Variant | Status | Available | Current price |
|---|---|---|---|
| MW-R16 | available | — | Contact |
Get a price for the Multiway MW-R16 AMR Reach Truck
We work from Hangzhou with Chinese and international robot makers. Tell us what you need and we check the current price, lead time and delivery to your country, and reply by email. Our fee comes from you, never from the seller.
A real person reads this. Reply within 2 business days. How we help buyers of robots from China →
Not sure it can do the job? We simulate the task before you buy →
Full price history
| Price | Date | Variant | Source | Note |
|---|---|---|---|---|
| Contact | 2026-10-17 | MW-R16 | Multiway Robotics (official) | No public price on the product page or datasheet; project-based quote. |
Sensors
- Navigation LiDAR (3D SLAM)
- Safety obstacle-avoidance LiDAR (bottom)
- Stereo obstacle avoidance
- Fork-tip photoelectric sensor
- Safety bumper
- Visual non-stop pallet pose identification and high-bay detection
Locomotion
wheeled reach truck, LiDAR 3D SLAM navigation
Manipulation
Arms: 0 DOF · Hands: Reach-mast pallet forks 1150x100x45 mm; lift up to 9,500 mm; 750 kg at max height; mast closed height 2,350-3,910 mm
Use cases
high-level pallet storage and retrieval, goods stacking and shelf access, production-line integration, automatic truck loading and unloading, cold-storage handling (customisable)
Key facts
- Official model page (fetched 2026-10-17) and R Series datasheet (PDF, R14/R16/R20): rated load 1,600 kg at 600 mm load centre, max lift 9,500 mm, 750 kg at max height, turning radius 1,710 mm, dimensions 2,555 x 1,455 x 2,350-3,910 mm.
- Speed: 2 m/s no load / 1.5 m/s full load (datasheet); max_speed_ms is the unloaded figure, km/h converted. Third-party sites quote 2.6 m/s and 11.5 m lift; neither appears in Multiway documents and they are not used.
- Battery: datasheet 48 V / 450 Ah, run time 8-10 h, 2,500 cycles to 70%. battery_wh = 21,600 Wh is computed (48 x 450); runtime is a range, so battery_hours is null. The model page's battery rows are mis-labelled; the datasheet was used.
- The datasheet intro paragraph says the R series supports 'a maximum load of 2500 kg'; its own table tops out at 2,000 kg (R20), so the table is used. Datasheet weight 3,010-3,390 kg is one range for R14/R16, so weight_kg is null.
- Datasheet says parameters are 'for reference only'. The datasheet lists aisle width 3,100 mm in a merged R14/R16 cell (3,200 mm for R20); not stored as a spec field. IP rating, operating temperature and certifications are not published, so null. Price not published.
- Siblings on the same page: MW-R20S (2,000 kg, 8,500 mm lift), not in the catalog.
- Image: Multiway product photo https://www.mw-r.com/uploads/images/20250814/20744f92e89f8d82c739775dfe0e4b9a.png (750x750 PNG, official model page), placed on white at 800x534.
About Multiway Robotics
Shenzhen intralogistics robotics maker of autonomous forklifts (counterbalanced, reach, VNA, sideloader, pallet stacker/truck), AMR tuggers and four-way shuttles, plus WMS, RCS, WCS and vision software. Production in Wuzhen, Zhejiang; subsidiaries in the US, Germany, Japan and South Korea.
https://www.mw-r.com · Founded: 2019 · HQ: Shenzhen, China
Last updated: 2026-10-17 · Full dataset (CSV/JSON, CC BY 4.0)